OpenRoadCode
Public API reference for OpenRoadCode

Define access to acceleration and angular velocity data. More...
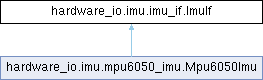
Public Member Functions | |
| None | start (self) |
| Initialize the IMU device. | |
| None | stop (self) |
| Release resources associated with the IMU device. | |
| bool | is_connected (self) |
| Return whether the IMU is initialized and available. | |
| Vector3 | get_acceleration_mps2 (self) |
| Read acceleration. | |
| Vector3 | get_angular_velocity_rad_s (self) |
| Read angular velocity. | |
Define access to acceleration and angular velocity data.
| Vector3 hardware_io.imu.imu_if.ImuIf.get_acceleration_mps2 | ( | self | ) |
Read acceleration.
Reimplemented in hardware_io.imu.mpu6050_imu.Mpu6050Imu.
| Vector3 hardware_io.imu.imu_if.ImuIf.get_angular_velocity_rad_s | ( | self | ) |
Read angular velocity.
Reimplemented in hardware_io.imu.mpu6050_imu.Mpu6050Imu.
| bool hardware_io.imu.imu_if.ImuIf.is_connected | ( | self | ) |
Return whether the IMU is initialized and available.
| True | The IMU is initialized and readable. |
| False | The IMU is disconnected. |
Reimplemented in hardware_io.imu.mpu6050_imu.Mpu6050Imu.