OpenRoadCode
Public API reference for OpenRoadCode

Provide accelerometer and gyroscope data from an MPU-6050. More...
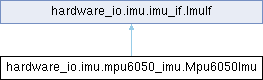
Public Member Functions | |
| None | __init__ (self, Any|None i2c_bus=None, int address=DEFAULT_ADDRESS) |
| Initialize the MPU-6050 driver configuration. | |
| None | start (self) |
| Initialize the I2C bus and MPU-6050 sensor. | |
| None | stop (self) |
| Release resources owned by the MPU-6050 driver. | |
| bool | is_connected (self) |
| Return whether the MPU-6050 has been initialized. | |
| Vector3 | get_acceleration_mps2 (self) |
| Return acceleration along each axis in meters per second squared. | |
| Vector3 | get_angular_velocity_rad_s (self) |
| Return angular velocity along each axis in radians per second. | |
Protected Member Functions | |
| Any | _require_sensor (self) |
| Return the initialized sensor or raise an error. | |
| None | _release_i2c_bus (self) |
| Release the internally created I2C bus. | |
Provide accelerometer and gyroscope data from an MPU-6050.
| None hardware_io.imu.mpu6050_imu.Mpu6050Imu.__init__ | ( | self, | |
| Any | None | i2c_bus = None, |
||
| int | address = DEFAULT_ADDRESS |
||
| ) |
Initialize the MPU-6050 driver configuration.
Args: i2c_bus: Optional existing CircuitPython-compatible I2C bus. When omitted, the driver creates the default board I2C bus.
address:
I2C address of the MPU-6050. The default address is 0x68.