OpenRoadCode
Public API reference for OpenRoadCode

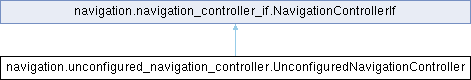
Report that navigation support has not been configured. More...
Public Member Functions | |
| bool | is_started (self) |
| Return whether the controller is ready to read state. | |
| bool | is_available (self) |
| Return whether navigation support is configured and available. | |
| str|None | status_message (self) |
| Return an availability message, if one applies. | |
| MotionCalibration|None | calibration (self) |
| Return the active stationary calibration, if any. | |
| None | start (self) |
| Start the controller and its configured sources. | |
| None | stop (self) |
| Stop the controller and its configured sources. | |
| None | reset_heading (self, float heading_deg=0.0) |
| Reset relative heading to the requested number of degrees. | |
| MotionCalibration | calibrate_stationary (self, int sample_count=100, float sample_interval_s=0.01) |
| Measure motion-sensor biases while stationary. | |
| None | update_gps_state (self, GpsState gps_state) |
| Accept the latest normalized GPS report. | |
| NavigationState | read_state (self) |
| Read and return the current navigation state. | |
Report that navigation support has not been configured.
| MotionCalibration navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.calibrate_stationary | ( | self, | |
| int | sample_count = 100, |
||
| float | sample_interval_s = 0.01 |
||
| ) |
Measure motion-sensor biases while stationary.
| sample_count | Number of stationary samples to collect. |
| sample_interval_s | Delay between samples in seconds. |
Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.
| MotionCalibration | None navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.calibration | ( | self | ) |
Return the active stationary calibration, if any.
None before calibration. Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.
| bool navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.is_available | ( | self | ) |
Return whether navigation support is configured and available.
| True | Navigation support is available. |
| False | Navigation support is unavailable. |
Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.
| bool navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.is_started | ( | self | ) |
Return whether the controller is ready to read state.
| True | The controller has been started. |
| False | The controller has not been started. |
Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.
| NavigationState navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.read_state | ( | self | ) |
Read and return the current navigation state.
Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.
| None navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.reset_heading | ( | self, | |
| float | heading_deg = 0.0 |
||
| ) |
Reset relative heading to the requested number of degrees.
| heading_deg | Desired heading after resetting, in degrees. |
Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.
| str | None navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.status_message | ( | self | ) |
Return an availability message, if one applies.
None when no message applies. Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.
| None navigation.unconfigured_navigation_controller.UnconfiguredNavigationController.update_gps_state | ( | self, | |
| GpsState | gps_state | ||
| ) |
Accept the latest normalized GPS report.
| gps_state | Latest normalized GPS state. |
Reimplemented from navigation.navigation_controller_if.NavigationControllerIf.