OpenRoadCode
Public API reference for OpenRoadCode

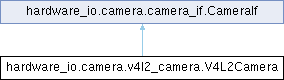
Capture frames from a Linux V4L2 camera device. More...
Public Member Functions | |
| bool | is_open (self) |
| Return whether the camera device is currently open. | |
| None | open (self) |
| Open and configure the camera device. | |
| CameraFrame | read (self) |
| Capture and return the next frame. | |
| None | close (self) |
| Release the camera device. | |
Capture frames from a Linux V4L2 camera device.
OpenCV is imported lazily so simply importing OpenRoadCode does not make camera support a mandatory dependency on systems that do not use it.
| bool hardware_io.camera.v4l2_camera.V4L2Camera.is_open | ( | self | ) |
Return whether the camera device is currently open.
Reimplemented from hardware_io.camera.camera_if.CameraIf.
| CameraFrame hardware_io.camera.v4l2_camera.V4L2Camera.read | ( | self | ) |
Capture and return the next frame.
Reimplemented from hardware_io.camera.camera_if.CameraIf.