OpenRoadCode
Public API reference for OpenRoadCode

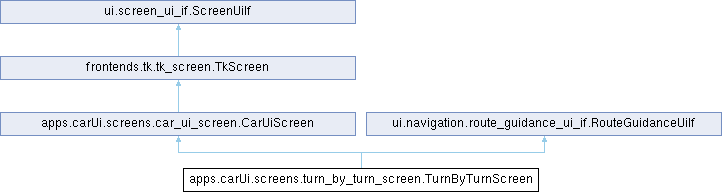
Render toolkit-neutral route-guidance presentation state. More...
Public Member Functions | |
| None | set_simulation_action (self, Callable[[], None] action) |
| Install the temporary development action for route simulation. | |
| None | show (self) |
| Build and display this screen's Tk panels. | |
| None | hide (self) |
| Release transient screen activity before navigating away. | |
| None | set_instruction (self, str|None instruction) |
| Set the current maneuver instruction. | |
| None | set_distance_to_maneuver (self, float|None distance_m) |
| Set distance remaining until the current maneuver. | |
| None | set_distance_remaining (self, float|None distance_m) |
| Set total route distance remaining. | |
| None | set_off_route (self, bool off_route) |
| Set whether the vehicle is currently off route. | |
| None | set_route_complete (self, bool complete) |
| Set whether the destination has been reached. | |
 Public Member Functions inherited from frontends.tk.tk_screen.TkScreen | |
| ScreenId | screen_id (self) |
| Return the stable identifier used to navigate to this screen. | |
| bool | handle_ui_action (self, UiAction action) |
| Return False until a screen provides semantic action handling. | |
Render toolkit-neutral route-guidance presentation state.
| None apps.carUi.screens.turn_by_turn_screen.TurnByTurnScreen.set_distance_remaining | ( | self, | |
| float | None | distance_m | ||
| ) |
Set total route distance remaining.
| distance_m | Remaining route distance in meters, or None when unavailable. |
Reimplemented from ui.navigation.route_guidance_ui_if.RouteGuidanceUiIf.
| None apps.carUi.screens.turn_by_turn_screen.TurnByTurnScreen.set_distance_to_maneuver | ( | self, | |
| float | None | distance_m | ||
| ) |
Set distance remaining until the current maneuver.
| distance_m | Distance to the maneuver in meters, or None when unavailable. |
Reimplemented from ui.navigation.route_guidance_ui_if.RouteGuidanceUiIf.
| None apps.carUi.screens.turn_by_turn_screen.TurnByTurnScreen.set_instruction | ( | self, | |
| str | None | instruction | ||
| ) |
Set the current maneuver instruction.
| instruction | Human-readable maneuver instruction, or None when unavailable. |
Reimplemented from ui.navigation.route_guidance_ui_if.RouteGuidanceUiIf.
| None apps.carUi.screens.turn_by_turn_screen.TurnByTurnScreen.set_off_route | ( | self, | |
| bool | off_route | ||
| ) |
Set whether the vehicle is currently off route.
| off_route | True when the vehicle is considered off the active route. |
Reimplemented from ui.navigation.route_guidance_ui_if.RouteGuidanceUiIf.
| None apps.carUi.screens.turn_by_turn_screen.TurnByTurnScreen.set_route_complete | ( | self, | |
| bool | complete | ||
| ) |
Set whether the destination has been reached.
| complete | True when route guidance has reached the destination. |
Reimplemented from ui.navigation.route_guidance_ui_if.RouteGuidanceUiIf.